Em đã giải quyết được vấn đề truyền sai kí tự (mặc dù chỉ thử dc kí tự 3 và 6 là đúng hoàn toàn :d ) nhưng sao mà cứ cho hàm delay_ms(1000) vào là ko chạy đc nữa nhỉ? Ai có thể giải thích cho em lỗi ở đâu dc ko? Thank!
-
-
Hịc, mình đã tìm ra nguyên nhân, hóa ra là con atmega16L bị hỏng phần truyền nhận dữ liệu với máy tính, mặc dù các phần khác vẫn dùng ngon Đúng là cái bọn chợ Trời toàn bán đồ lởm ^_^
Comment
-
Vấn đề truyền sai trong proteus là do các cổng tín hiệu trong Max232 là cổng đảo (Khác so với max232 thực tế) -> tín hiệu bị đảo -> phải thêm NOT để đảm bảo tín hiệu đúng.----------------------
Bể học là mênh mông!Comment
-
Ngyên nhân là gi thế bạn mình cũng đang làm về vấn đề này mình muốn chuyền con số nhận được từ cảm biến lên máy tínhNguyên văn bởi yen_trang Xem bài viết
Vấn đề của bạn có lẽ là do hàm putchar của bạn thôi bạn thư putchar('4') ;putchar('9');thử xem nhéComment
-
Làm sao để gửi dc chuổi 1000.
Theo mình biết hàm putchar( ) chỉ gửi được có 1 ký tự thôi.
Mình dùng hàm puts( ) để gửi chuổi 1000.
Các bạn ai biết dùng putchar( ) để gửi số 1000 chỉ mình nhé.
Thanks các bạn.Phone: 0909319477
Email:
Comment
-
Mình đang mắc phần này, cũng không làm sao chạy được.
Đây là code của em:
/************************************************** ***
Chip type : ATmega16
Program type : Application
Clock frequency : 16.000000 MHz
Memory model : Small
External SRAM size : 0
Data Stack size : 256
************************************************** ***/
#include <mega16.h>
#include <delay.h>
// Standard Input/Output functions
#include <stdio.h>
// Alphanumeric LCD Module functions
#asm
.equ __lcd_port=0x15 ;PORTC
#endasm
#include <lcd.h>
#define RXB8 1
#define TXB8 0
#define UPE 2
#define OVR 3
#define FE 4
#define UDRE 5
#define RXC 7
#define FRAMING_ERROR (1<<FE)
#define PARITY_ERROR (1<<UPE)
#define DATA_OVERRUN (1<<OVR)
#define DATA_REGISTER_EMPTY (1<<UDRE)
#define RX_COMPLETE (1<<RXC)
// USART Receiver buffer
#define RX_BUFFER_SIZE 8
char rx_buffer[RX_BUFFER_SIZE];
#if RX_BUFFER_SIZE<256
unsigned char rx_wr_index,rx_rd_index,rx_counter;
#else
unsigned int rx_wr_index,rx_rd_index,rx_counter;
#endif
// This flag is set on USART Receiver buffer overflow
bit rx_buffer_overflow;
// USART Receiver interrupt service routine
interrupt [USART_RXC] void usart_rx_isr(void)
{
/*char status,data;
status=UCSRA;
data=UDR;
if ((status & (FRAMING_ERROR | PARITY_ERROR | DATA_OVERRUN))==0)
{
rx_buffer[rx_wr_index]=data;
if (++rx_wr_index == RX_BUFFER_SIZE) rx_wr_index=0;
if (++rx_counter == RX_BUFFER_SIZE)
{
rx_counter=0;
rx_buffer_overflow=1;
};
};
}
#ifndef _DEBUG_TERMINAL_IO_
// Get a character from the USART Receiver buffer
#define _ALTERNATE_GETCHAR_
#pragma used+
char getchar(void)
{
char data;
while (rx_counter==0);
data=rx_buffer[rx_rd_index];
if (++rx_rd_index == RX_BUFFER_SIZE) rx_rd_index=0;
#asm("cli")
--rx_counter;
#asm("sei")
return data;
}
#pragma used-
#endif
// USART Transmitter buffer
#define TX_BUFFER_SIZE 8
char tx_buffer[TX_BUFFER_SIZE];
#if TX_BUFFER_SIZE<256
unsigned char tx_wr_index,tx_rd_index,tx_counter;
#else
unsigned int tx_wr_index,tx_rd_index,tx_counter;
#endif
// USART Transmitter interrupt service routine
interrupt [USART_TXC] void usart_tx_isr(void)
{
if (tx_counter)
{
--tx_counter;
UDR=tx_buffer[tx_rd_index];
if (++tx_rd_index == TX_BUFFER_SIZE) tx_rd_index=0;
};
}
#ifndef _DEBUG_TERMINAL_IO_
// Write a character to the USART Transmitter buffer
#define _ALTERNATE_PUTCHAR_
#pragma used+
void putchar(char c)
{
while (tx_counter == TX_BUFFER_SIZE);
#asm("cli")
if (tx_counter || ((UCSRA & DATA_REGISTER_EMPTY)==0))
{
tx_buffer[tx_wr_index]=c;
if (++tx_wr_index == TX_BUFFER_SIZE) tx_wr_index=0;
++tx_counter;
}
else
UDR=c;
#asm("sei")
}
#pragma used-
#endif
// Declare your global variables here
void main(void)
{
unsigned char count;
// Input/Output Ports initialization
// Port A initialization
PORTA=0x00;
DDRA=0x00;
// Port B initialization
PORTB=0x00;
DDRB=0xB0;
// Port C initialization
PORTC=0x00;
DDRC=0xFF;
// Port D initialization
PORTD=0x00;
DDRD=0x00;
TCCR0=0x00;
TCNT0=0x00;
OCR0=0x00;
TCCR1A=0x00;
TCCR1B=0x00;
TCNT1H=0x00;
TCNT1L=0x00;
ICR1H=0x00;
ICR1L=0x00;
OCR1AH=0x00;
OCR1AL=0x00;
OCR1BH=0x00;
OCR1BL=0x00;
ASSR=0x00;
TCCR2=0x00;
TCNT2=0x00;
OCR2=0x00;
MCUCR=0x00;
MCUCSR=0x00;
// Timer(s)/Counter(s) Interrupt(s) initialization
TIMSK=0x00;
// USART initialization
// Communication Parameters: 8 Data, 1 Stop, No Parity
// USART Receiver: On
// USART Transmitter: On
// USART Mode: Asynchronous
// USART Baud rate: 9600
UCSRA=0x00;
UCSRB=0xD8;
UCSRC=0x86;
UBRRH=0x00;
UBRRL=0x67;
ACSR=0x80;
SFIOR=0x00;
// Global enable interrupts
#asm("sei")
count = 10;
while (1)
{
putchar(count);
delay_ms(100);
count++;
};
}Comment
-
-
Bạn thử thay PORTD và DDRD bằng các giá trị này thử nhé.Mình đang mắc phần này, cũng không làm sao chạy được.
Đây là code của em:
Trích:
/************************************************** ***
Chip type : ATmega16
Program type : Application
Clock frequency : 16.000000 MHz
Memory model : Small
External SRAM size : 0
Data Stack size : 256
************************************************** ***/
#include <mega16.h>
#include <delay.h>
// Standard Input/Output functions
#include <stdio.h>
// Alphanumeric LCD Module functions
#asm
.equ __lcd_port=0x15 ;PORTC
#endasm
#include <lcd.h>
#define RXB8 1
#define TXB8 0
#define UPE 2
#define OVR 3
#define FE 4
#define UDRE 5
#define RXC 7
#define FRAMING_ERROR (1<<FE)
#define PARITY_ERROR (1<<UPE)
#define DATA_OVERRUN (1<<OVR)
#define DATA_REGISTER_EMPTY (1<<UDRE)
#define RX_COMPLETE (1<<RXC)
// USART Receiver buffer
#define RX_BUFFER_SIZE 8
char rx_buffer[RX_BUFFER_SIZE];
#if RX_BUFFER_SIZE<256
unsigned char rx_wr_index,rx_rd_index,rx_counter;
#else
unsigned int rx_wr_index,rx_rd_index,rx_counter;
#endif
// This flag is set on USART Receiver buffer overflow
bit rx_buffer_overflow;
// USART Receiver interrupt service routine
interrupt [USART_RXC] void usart_rx_isr(void)
{
/*char status,data;
status=UCSRA;
data=UDR;
if ((status & (FRAMING_ERROR | PARITY_ERROR | DATA_OVERRUN))==0)
{
rx_buffer[rx_wr_index]=data;
if (++rx_wr_index == RX_BUFFER_SIZE) rx_wr_index=0;
if (++rx_counter == RX_BUFFER_SIZE)
{
rx_counter=0;
rx_buffer_overflow=1;
};
};
}
#ifndef _DEBUG_TERMINAL_IO_
// Get a character from the USART Receiver buffer
#define _ALTERNATE_GETCHAR_
#pragma used+
char getchar(void)
{
char data;
while (rx_counter==0);
data=rx_buffer[rx_rd_index];
if (++rx_rd_index == RX_BUFFER_SIZE) rx_rd_index=0;
#asm("cli")
--rx_counter;
#asm("sei")
return data;
}
#pragma used-
#endif
// USART Transmitter buffer
#define TX_BUFFER_SIZE 8
char tx_buffer[TX_BUFFER_SIZE];
#if TX_BUFFER_SIZE<256
unsigned char tx_wr_index,tx_rd_index,tx_counter;
#else
unsigned int tx_wr_index,tx_rd_index,tx_counter;
#endif
// USART Transmitter interrupt service routine
interrupt [USART_TXC] void usart_tx_isr(void)
{
if (tx_counter)
{
--tx_counter;
UDR=tx_buffer[tx_rd_index];
if (++tx_rd_index == TX_BUFFER_SIZE) tx_rd_index=0;
};
}
#ifndef _DEBUG_TERMINAL_IO_
// Write a character to the USART Transmitter buffer
#define _ALTERNATE_PUTCHAR_
#pragma used+
void putchar(char c)
{
while (tx_counter == TX_BUFFER_SIZE);
#asm("cli")
if (tx_counter || ((UCSRA & DATA_REGISTER_EMPTY)==0))
{
tx_buffer[tx_wr_index]=c;
if (++tx_wr_index == TX_BUFFER_SIZE) tx_wr_index=0;
++tx_counter;
}
else
UDR=c;
#asm("sei")
}
#pragma used-
#endif
// Declare your global variables here
void main(void)
{
unsigned char count;
// Input/Output Ports initialization
// Port A initialization
PORTA=0x00;
DDRA=0x00;
// Port B initialization
PORTB=0x00;
DDRB=0xB0;
// Port C initialization
PORTC=0x00;
DDRC=0xFF;
// Port D initialization
PORTD=0x01;
DDRD=0x02;
TCCR0=0x00;
TCNT0=0x00;
OCR0=0x00;
TCCR1A=0x00;
TCCR1B=0x00;
TCNT1H=0x00;
TCNT1L=0x00;
ICR1H=0x00;
ICR1L=0x00;
OCR1AH=0x00;
OCR1AL=0x00;
OCR1BH=0x00;
OCR1BL=0x00;
ASSR=0x00;
TCCR2=0x00;
TCNT2=0x00;
OCR2=0x00;
MCUCR=0x00;
MCUCSR=0x00;
// Timer(s)/Counter(s) Interrupt(s) initialization
TIMSK=0x00;
// USART initialization
// Communication Parameters: 8 Data, 1 Stop, No Parity
// USART Receiver: On
// USART Transmitter: On
// USART Mode: Asynchronous
// USART Baud rate: 9600
UCSRA=0x00;
UCSRB=0xD8;
UCSRC=0x86;
UBRRH=0x00;
UBRRL=0x67;
ACSR=0x80;
SFIOR=0x00;
// Global enable interrupts
#asm("sei")
count = 10;
while (1)
{
putchar(count);
delay_ms(100);
count++;
};
}
PORTD=0x01;
DDRD=0x02;
Chú ý: PORTD.0 là chân nhận dữ liệu nên phải khai báo là input.
PORTD.1 là chân truyền dữ liệu nên phải khai báo là output.Phone: 0909319477
Email:
Comment
-
Theo mình, bạn nên kiểm tra lại phần cứng, lưu ý kết nối Rx ben phia mạch kết nối với Tx bên PC va ngược lại. Code ko có vấn đề gìNguyên văn bởi thanhtuandkh Xem bài viếtComment
-
Cảm ơn bác đã hướng dẫn nhưng em thấy khi định cấu hình sử dụng UART thì việc khai báo DDR của pin TX và RX là không cần thiết.Nguyên văn bởi lehanhla Xem bài viết
Mặt khác em cũng đã thử nhưng ...kết quả vẫn im re. KHông thể bắn được lên máy tính.
Bác nào đã từng làm món này giúp em với .....Comment
-
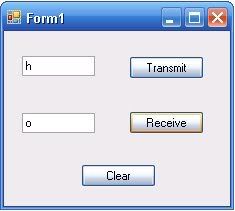
Đoạn code này mình viết cho con Atmega32, mình test okie rồi.
Mình cũng thử truyền bằng giao diện, thấy cũng Okie
 Last edited by lehanhla; 24-04-2009, 15:56.Phone: 0909319477
Email:
Comment
-
Các bác xem giúp em đoạn cốt này với em muốn truyền con số thu được từ cảm biến qua adc lên vi điều khiển nhưng mà em mô phỏng bằng proteus thử thì không được nó hiện kí tự lung tung quá không ra những con số mà cảm biến thu được
Em khởi tạo tần số dao động của atmega16 là 8 mhz với sai số của khung truyền là 0.2% liệu đây có phải là nguyên nhân truyền sai không nhỉ các bác ?
Em thử mô phỏng khởi tạo bằng codevision C với tần số chuẩn như 11.0592 để sai số khung truyền 0.0% thì truyền lên đúng những kí tự mà mình đã truyền nhưng với lỗi 0.2% thi lại không được các bác giải thích giúp em với !
Mong các bác giúp đỡ
#include <mega16.h>
#include<delay.h>
// Alphanumeric LCD Module functions
#asm
.equ __lcd_port=0x18 ;PORTB
#endasm
#include <lcd.h>
#define RXB8 1
#define TXB8 0
#define UPE 2
#define OVR 3
#define FE 4
#define UDRE 5
#define RXC 7
#define FRAMING_ERROR (1<<FE)
#define PARITY_ERROR (1<<UPE)
#define DATA_OVERRUN (1<<OVR)
#define DATA_REGISTER_EMPTY (1<<UDRE)
#define RX_COMPLETE (1<<RXC)
// USART Receiver buffer
#define RX_BUFFER_SIZE 8
char rx_buffer[RX_BUFFER_SIZE];
#if RX_BUFFER_SIZE<256
unsigned char rx_wr_index,rx_rd_index,rx_counter;
#else
unsigned int rx_wr_index,rx_rd_index,rx_counter;
#endif
// This flag is set on USART Receiver buffer overflow
bit rx_buffer_overflow;
// USART Receiver interrupt service routine
interrupt [USART_RXC] void usart_rx_isr(void)
{
char status,data;
status=UCSRA;
data=UDR;
if ((status & (FRAMING_ERROR | PARITY_ERROR | DATA_OVERRUN))==0)
{
rx_buffer[rx_wr_index]=data;
if (++rx_wr_index == RX_BUFFER_SIZE) rx_wr_index=0;
if (++rx_counter == RX_BUFFER_SIZE)
{
rx_counter=0;
rx_buffer_overflow=1;
};
};
}
#ifndef _DEBUG_TERMINAL_IO_
// Get a character from the USART Receiver buffer
#define _ALTERNATE_GETCHAR_
#pragma used+
char getchar(void)
{
char data;
while (rx_counter==0);
data=rx_buffer[rx_rd_index];
if (++rx_rd_index == RX_BUFFER_SIZE) rx_rd_index=0;
#asm("cli")
--rx_counter;
#asm("sei")
return data;
}
#pragma used-
#endif
// USART Transmitter buffer
#define TX_BUFFER_SIZE 8
char tx_buffer[TX_BUFFER_SIZE];
#if TX_BUFFER_SIZE<256
unsigned char tx_wr_index,tx_rd_index,tx_counter;
#else
unsigned int tx_wr_index,tx_rd_index,tx_counter;
#endif
// USART Transmitter interrupt service routine
interrupt [USART_TXC] void usart_tx_isr(void)
{
if (tx_counter)
{
--tx_counter;
UDR=tx_buffer[tx_rd_index];
if (++tx_rd_index == TX_BUFFER_SIZE) tx_rd_index=0;
};
}
#ifndef _DEBUG_TERMINAL_IO_
// Write a character to the USART Transmitter buffer
#define _ALTERNATE_PUTCHAR_
#pragma used+
void putchar(char c)
{
while (tx_counter == TX_BUFFER_SIZE);
#asm("cli")
if (tx_counter || ((UCSRA & DATA_REGISTER_EMPTY)==0))
{
tx_buffer[tx_wr_index]=c;
if (++tx_wr_index == TX_BUFFER_SIZE) tx_wr_index=0;
++tx_counter;
}
else
UDR=c;
#asm("sei")
}
#pragma used-
#endif
// Standard Input/Output functions
#include <stdio.h>
#define FIRST_ADC_INPUT 0
#define LAST_ADC_INPUT 1
unsigned char adc_data[LAST_ADC_INPUT-FIRST_ADC_INPUT+1];
#define ADC_VREF_TYPE 0x20
// ADC interrupt service routine
// with auto input scanning
interrupt [ADC_INT] void adc_isr(void)
{
register static unsigned char input_index=0;
// Read the 8 most significant bits
// of the AD conversion result
adc_data[input_index]=ADCH;
// Select next ADC input
if (++input_index > (LAST_ADC_INPUT-FIRST_ADC_INPUT))
input_index=0;
ADMUX=(FIRST_ADC_INPUT|ADC_VREF_TYPE)+input_index;
// Start the AD conversion
ADCSRA|=0x40;
}
// Declare your global variables here
void lcd_putnum(unsigned char so,unsigned char x,unsigned char y)
{
unsigned char a,b,c;
a=so/100;
b=(so-100*a)/10
c=(so-100*a-10*b);
lcd_gotoxy(x,y);
lcd_putchar(a+48);
lcd_putchar(b+48);
lcd_putchar(c+48);
}
void chuyendoi(unsigned char so)
{
unsigned char a,b,c;
a=so/100;
b=(so-100*a)/10;
c=(so-100*a-10*b);
putchar('a');
delay_ms(300);
putchar('b');
delay_ms(300);
putchar('c');
delay_ms(300);
}
void main(void)
{
// Declare your local variables here
// Input/Output Ports initialization
// Port A initialization
// Func7=In Func6=In Func5=In Func4=In Func3=In Func2=In Func1=In Func0=In
// State7=T State6=T State5=T State4=T State3=T State2=T State1=T State0=T
PORTA=0x00;
DDRA=0x00;
// Port B initialization
// Func7=In Func6=In Func5=In Func4=In Func3=In Func2=In Func1=In Func0=In
// State7=T State6=T State5=T State4=T State3=T State2=T State1=T State0=T
PORTB=0x00;
DDRB=0x00;
// Port C initialization
// Func7=In Func6=In Func5=In Func4=In Func3=In Func2=In Func1=In Func0=In
// State7=T State6=T State5=T State4=T State3=T State2=T State1=T State0=T
PORTC=0x00;
DDRC=0x00;
// Port D initialization
// Func7=In Func6=In Func5=In Func4=In Func3=In Func2=In Func1=In Func0=In
// State7=T State6=T State5=T State4=T State3=T State2=T State1=T State0=T
PORTD=0x00;
DDRD=0x00;
// Timer/Counter 0 initialization
// Clock source: System Clock
// Clock value: Timer 0 Stopped
// Mode: Normal top=FFh
// OC0 output: Disconnected
TCCR0=0x00;
TCNT0=0x00;
OCR0=0x00;
// Timer/Counter 1 initialization
// Clock source: System Clock
// Clock value: Timer 1 Stopped
// Mode: Normal top=FFFFh
// OC1A output: Discon.
// OC1B output: Discon.
// Noise Canceler: Off
// Input Capture on Falling Edge
// Timer 1 Overflow Interrupt: Off
// Input Capture Interrupt: Off
// Compare A Match Interrupt: Off
// Compare B Match Interrupt: Off
TCCR1A=0x00;
TCCR1B=0x00;
TCNT1H=0x00;
TCNT1L=0x00;
ICR1H=0x00;
ICR1L=0x00;
OCR1AH=0x00;
OCR1AL=0x00;
OCR1BH=0x00;
OCR1BL=0x00;
// Timer/Counter 2 initialization
// Clock source: System Clock
// Clock value: Timer 2 Stopped
// Mode: Normal top=FFh
// OC2 output: Disconnected
ASSR=0x00;
TCCR2=0x00;
TCNT2=0x00;
OCR2=0x00;
// External Interrupt(s) initialization
// INT0: Off
// INT1: Off
// INT2: Off
MCUCR=0x00;
MCUCSR=0x00;
// Timer(s)/Counter(s) Interrupt(s) initialization
TIMSK=0x00;
// USART initialization
// Communication Parameters: 8 Data, 1 Stop, No Parity
// USART Receiver: On
// USART Transmitter: On
// USART Mode: Asynchronous
// USART Baud rate: 9600
UCSRA=0x00;
UCSRB=0xD8;
UCSRC=0x86;
UBRRH=0x00;
UBRRL=0x33;
// Analog Comparator initialization
// Analog Comparator: Off
// Analog Comparator Input Capture by Timer/Counter 1: Off
ACSR=0x80;
SFIOR=0x00;
// ADC initialization
// ADC Clock frequency: 125.000 kHz
// ADC Voltage Reference: AREF pin
// ADC Auto Trigger Source: None
// Only the 8 most significant bits of
// the AD conversion result are used
ADMUX=FIRST_ADC_INPUT|ADC_VREF_TYPE;
ADCSRA=0xCE;
// LCD module initialization
lcd_init(16);
// Global enable interrupts
#asm("sei")
while (1)
{
unsigned char x;
// Place your code here
lcd_putnum(2*adc_data[1],0,0);
// lcd_putnum(adc_data[0],0,1);
x=2*adc_data[1] ;
chuyendoi(x);
};
}Last edited by huetkiem; 24-04-2009, 22:06.Comment
-
Giúp mình về chuong trình nhận dư liệu bằng cổng com viết bằng c#
Chương trình nhận dữ liệu qua cổng com của mình nhận dữ liệu qua Com, ở tốc độ 9600 thì rất ngon, nhưng mà lên tốc độ 115200 thì dữ liệu tải lên toàn bị lỗi font và không đủ. Các bác giải thích giúp tớ được không?
: dữ liệu đẩy lên cứ 2 giây 1 lần có dạng:
lat:abc,long:abc,accuracy:72.4237,view:10;
code của tớ đây
delegate void SetTextCallback(string text); // Khai bao delegate SetTextCallBack voi tham so string
private void DataReceive(object obj, SerialDataReceivedEventArgs e)
{
try {
System.Threading.Thread.Sleep(3000);
InputData = P.ReadExisting();
}
catch { InputData = "Lỗi nhận từ COM."; }
string a = InputData;
if (a != String.Empty)
{
//txtkq.Text = InputData; // Ko dùng đc như thế này vì khác threads .
SetText(a); // Chính vì vậy phải sử dụng ủy quyền tại đây. Gọi delegate đã khai báo trước đó.
}
}
// Hàm của em nó là ở đây. Đừng hỏi vì sao lại thế.
private void SetText(string text)
{
string strText = DateTime.Now.ToString() + ": \n" + text + "\n";
if (this.txtkq.InvokeRequired)
{
SetTextCallback d = new SetTextCallback(SetText); // khởi tạo 1 delegate mới gọi đến SetText
this.Invoke(d, new object[] { strText });
}
else this.txtkq.Text = strText;
SaveGPSToDB(InputData);
}Comment
-
Bác mất căn bản quá, nhiều người cũng như bác vậy, code thấy um sùm, ghê gớm, nhưng hỏi là biết gà rồi. Code này chắc chép ở đâu.Comment


 Tìm hiểu thêm về yen_trang
 www.rpc.vn
Linh kiện cho
dự án của bạn Tra theo mã, xem datasheet và đặt hàng trực tuyến. MicrochipROHMEpsonTaejin
Đặt hàng & tư vấn
Hà Nội024.3640 8561
TP.HCM028.3811 9870
 Quét mã hoặc bấm để chat Zalo với R&PChat Zalo
-
 Trả lời cho Tìm bạn thân quen cũ.Còn sống không lão??? Mất một thời gian chữa bệnh nên quên hỏi thăm.......hôm nay, 03:09
-
Trả lời cho Công suất truyền qua lõi máy biến ápThời buổi năng lượng xanh, nhất là xanh cả mặt... Thì Điện mặt giời, điện gió, sẽ lên ngôi.
Nếu không nắm bắt được cái cơ bản đó thì đi làm coder à? Mà coder giờ thất nghiệp cả lũ vì AI rồi!!!


 ...
hôm nay, 03:03
-
 Trả lời cho Công suất truyền qua lõi máy biến ápChà, lâu lắm rồi nhưng diễn đàn vẫn còn những chủ đề cốt lõi của điện tử công suất...Hôm qua, 07:53
-
 Nếu muốn tăng công suất cần tăng con chip và tăng biến áp lên lớn hơn. Thiết kế ban đầu dùng TNY25x và biến áp EE16 hoặc EE13. Tăng con chip lên TNY268 vẫn mạch nguyên lý đó và biến áp lên EE19 sẽ nâng công suất ra thêm nhiều. Tăng tối đa...Hôm qua, 02:14
-
 Mạch này chỉ chạy cho LED 10W trở xuống, còn muốn chạy Led công suất cao thì sao bác thớt ơi?22-10-2026, 14:33
-
Mạch này chỉ chạy cho LED 10W trở xuống, còn muốn chạy Led công suất cao thì sao bác thớt ơi?22-10-2026, 10:49
-
 Trả lời cho Tìm VR 5 chânCảm ơn bác bqviet . Nhưng hình như các VR 5 chân của linhkienchatluong là loại có 2 chân là công tắc đóng mở. Thấy trên Shopee có chỗ bán linh kiện đàn Organ, mà không biết đúng loại không, với lại sao ... mắc dữ dội luôn ấy!!!
...19-10-2026, 11:30 -
Trả lời cho Tìm VR 5 chânTrang sản phẩm này có loại 5 chân và 8 chân
https://linhkienchatluong.vn/chiet-a...doi_s1595.aspx
Ngoài ra một trang cùng cấp với nó có loại 6 chân nữa, chắc đủ cho người muốn tìm....17-10-2026, 17:19 -
Chào cả nhà, chúc cuối tuần vui vẻ!
Hôm nay mình lên đây nhờ ai biết chỉ dùm biến trở 5 chân này tên gọi là gì, có thể mua ở đâu vậy? Xin cám ơn nhiều! ...
Comment